§  DregsBane Systems  ·  Virginia

Infrastructure against physical neglect.

CrustBot + Grime Ward · tools for care of public space

Public space gets neglected in the gap between full sanitation crews and doing nothing — corridor edges, plaza spillover, park hotspots, drain approaches. Places too small or too frequent to clean often enough at conventional cost.

We’re building two products for that work. CrustBot develops affordable, remotely operated hardware for cleanup. Grime Ward helps people discover places, keep photo journals and contribute cleanup evidence. Follow the robot build or explore the app’s beta.

Vehicle · assembly preparation

CrustBot

A simpler vehicle for the work ahead.
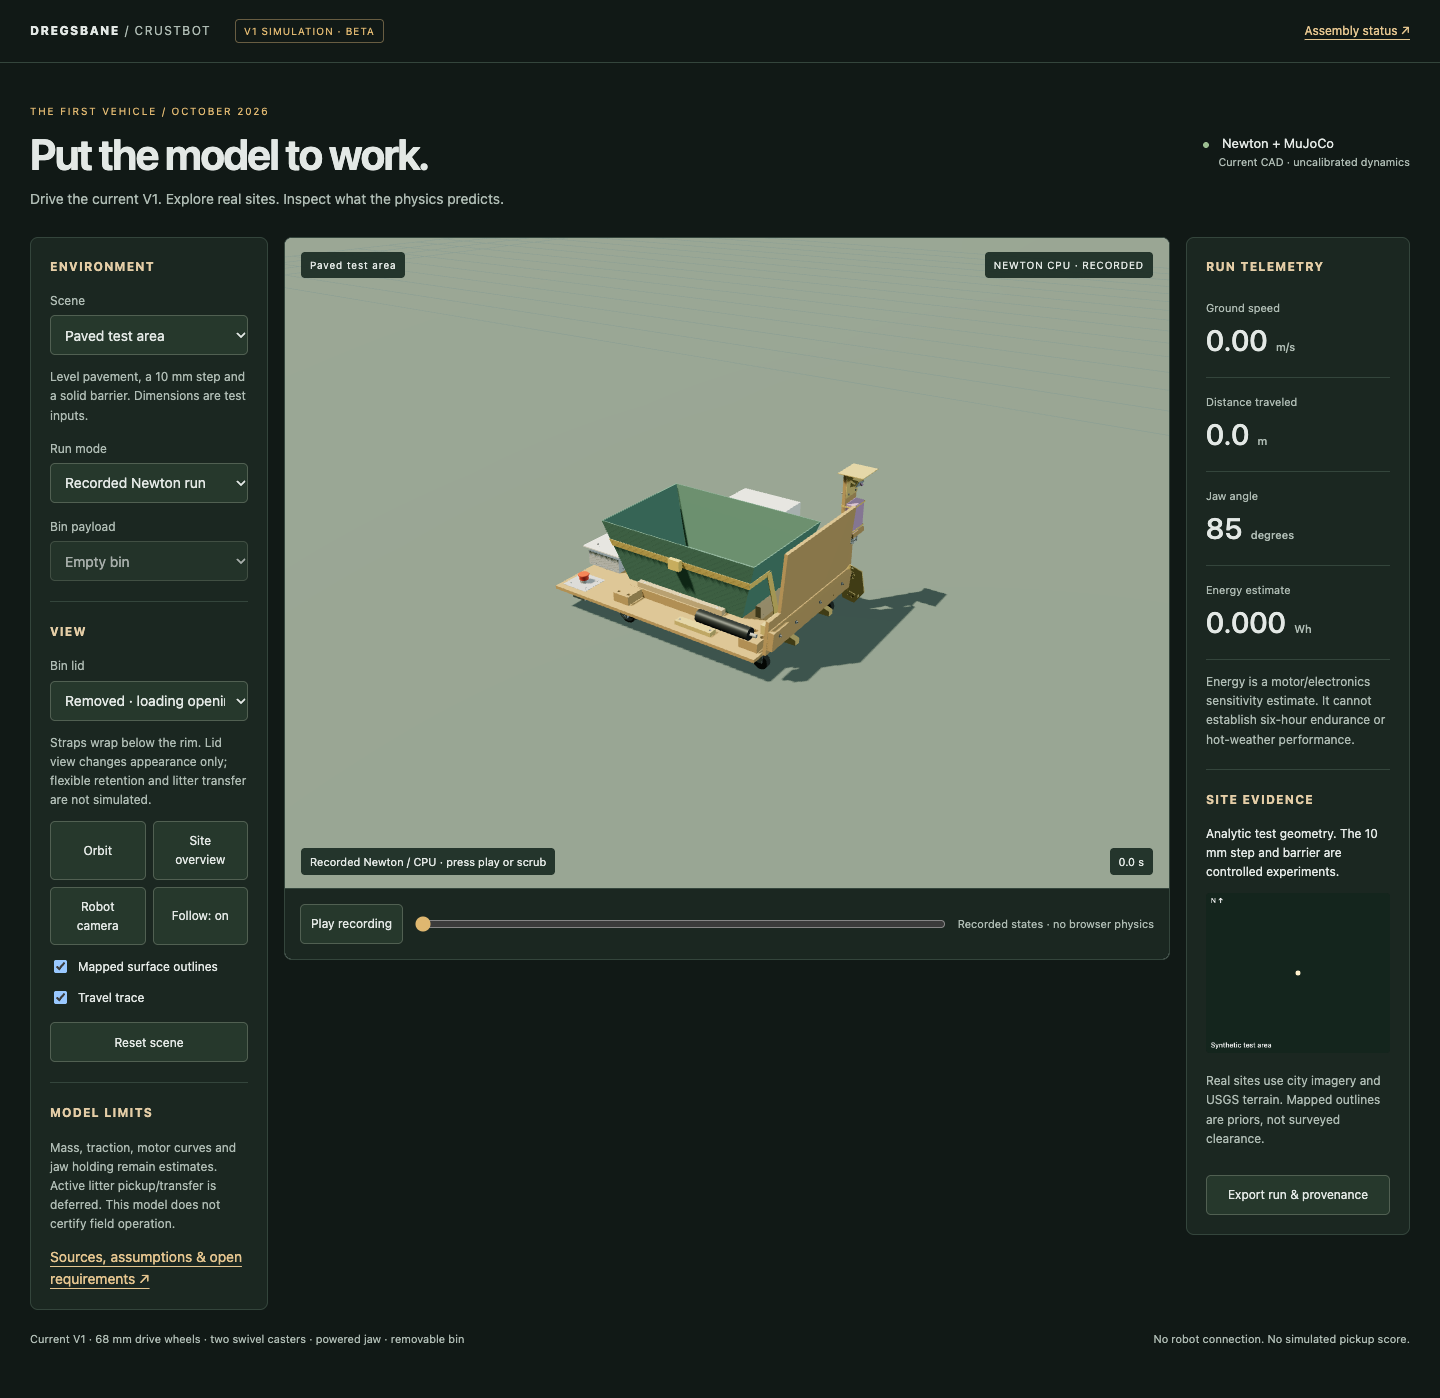
CrustBot V1 in the simulation lab, with its timber frame, powered jaw and open removable bin.

Current V1 simulation · uncalibrated dynamics

Remote drive, onboard camera perception, a powered jaw and a removable bin. The assembly packet is ready; physical commissioning comes next.

Materials
$604.29 planning estimate
Explore
Assembly viewer and physics simulator
Still ahead
Physical trials; automatic pickup and transfer
App · web beta

Grime Ward

Places worth noticing. Visits worth keeping.

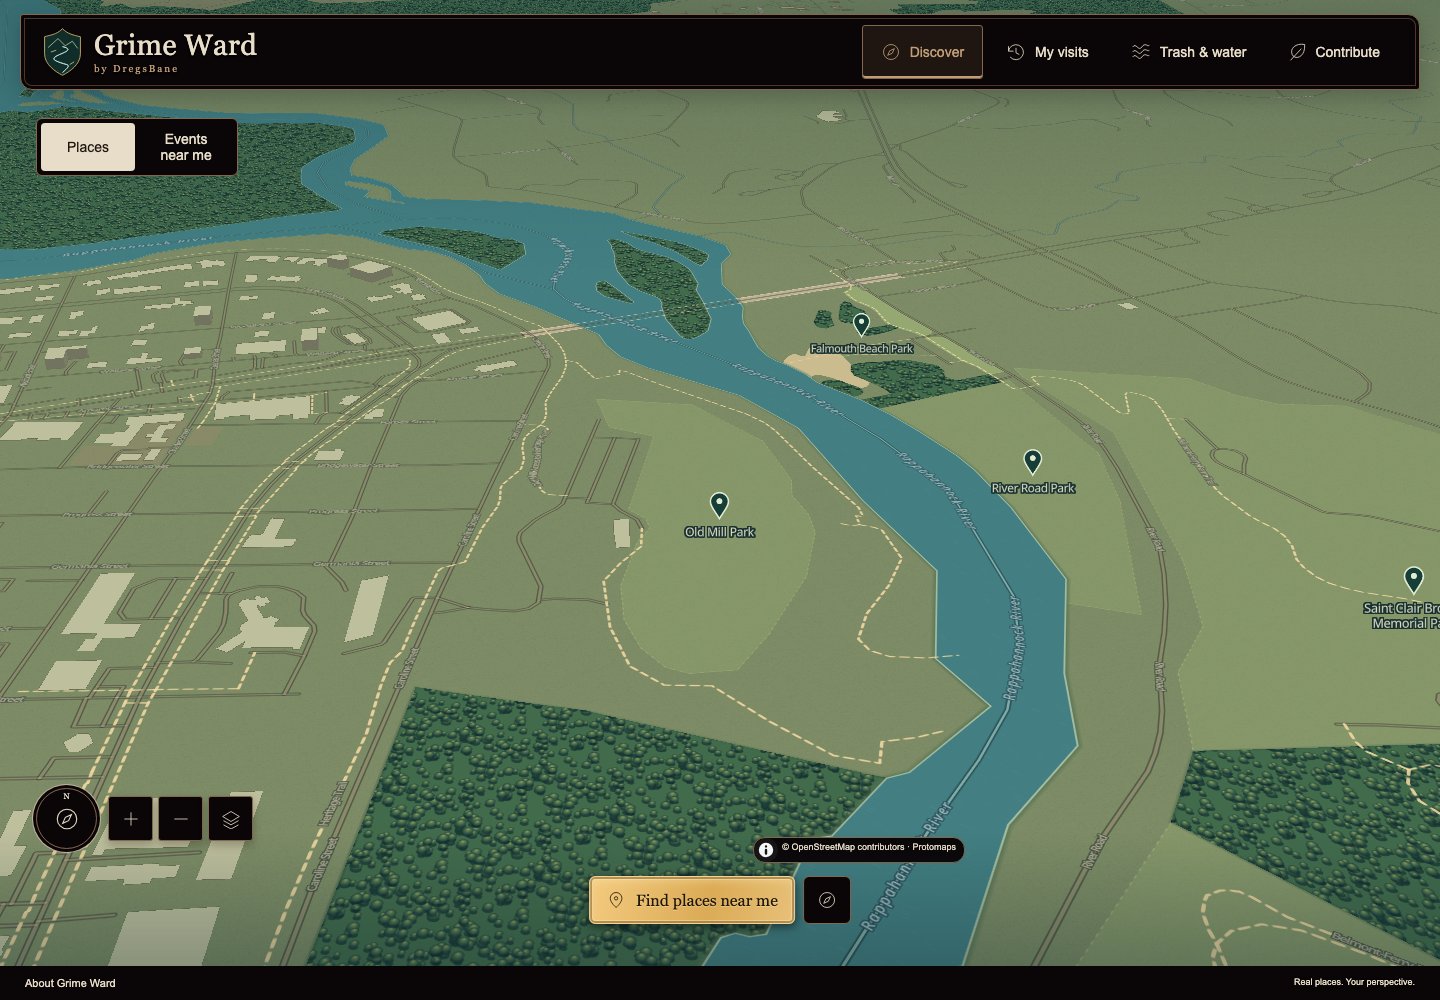
Grime Ward’s discovery map, with public places, nearby events and navigation to visits and shared contributions.

Current web beta · public-place discovery

Discover public places, keep dated photo visits and return to the same viewpoint. Share litter observations and completed cleanups when you choose.

Visits
Private on this device, with backup and restore
Explore
Places, events, litter and water context
Available
Web beta and internal TestFlight testing
§ 01 · Grime Ward · app in beta

Notice a place. Keep its story. Help care for it.

Grime Ward grows from Trash Trail's litter-and-water map into a place journal. Discover nearby public places, keep your own dated photographs and return to the same viewpoint. Share litter observations and completed cleanups when you choose.

Discover

Explore mapped public places and nearby events. Check local access and source dates; coverage varies.

Return

Keep private photos on this device, compare repeat viewpoints and export a backup. Journals are not account-synced.

Contribute

Explicitly share litter photos, help identify observations and record completed cleanup work with dates and organization credit.

Explore Grime Ward and its beta status →

§ 02 · Three layers

Build, observe and learn.

  1. 01 · assembly preparation

    CrustBot

    Remote driving, Pi 5 perception, Pico 2 control, a powered load-bearing jaw and a removable bin. The current design uses catalog drive parts, timber, plywood and selected printed mounts.

  2. 02 · beta

    Grime Ward

    Discover public places, document repeat visits and share litter observations and completed cleanups. Private device journals and the public observation commons have separate consent.

  3. 03 · future operation

    Route learning

    Use measured access, effort and before-and-after evidence to develop repeatable cleanup work. Service routes, automatic pickup and robot deployment still need their own trials.

§ 03 · The robot bench

CrustBot — ready to start the frame.

The first vehicle design includes remote control, Pi/camera perception, a powered jaw and a removable bin. Its plywood-and-timber frame has a checked assembly packet and a $604.29 planning material estimate. Active trash pickup and transfer come later. Physical commissioning, load tests and hot-weather endurance are still ahead.

October 15 build status and limits →

  1. Phase 0 CAD & software assembly package saved · desktop checks pass
  2. Phase 1 frame assembly instructions ready · unpowered build
  3. Phase 2 powered trials part fitting and physical tests pending · no field date
§ 04 · Operating principles

Frequency. Dignity. Proof. Serviceability.

01

Frequency

The failure mode isn't "never cleaned." It's "not cleaned often enough at the price point it would cost to do conventionally."

02

Dignity

Neglected physical space communicates neglect back to the people living around it.

03

Proof

Customers need evidence, not vibes. Every pickup is paired before / after. Every benchmark is reproducible.

04

Serviceability

Waste robotics only becomes real if the dirty parts are survivable and replaceable.

§ 05 · Where we are

Where we are.

Reviewed October 20, 2026. Robot engineering checkpoint: October 15; app release: October 9.

Grime Ward · web beta Discover public places, keep private photo visits on this device, revisit viewpoints, and explicitly share litter observations and cleanup records. Geographic coverage and evidence availability vary.
Grime Ward · iOS Version 1.0, build 9, delivered to the internal TestFlight group on October 9. Public App Store availability is not yet established.
Initial vehicle Remote driving, Pi 5 / IMX219 perception, powered load-bearing jaw and removable bin. Active litter pickup and transfer are deferred.
Frame assembly CAD, dimensioned workshop drawings, four-page bench packet and eight P1S print projects are prepared. Unpowered frame assembly can begin from the instructions.
Planning material cost $604.29, including $11 in unresolved fitting/price allowances. Owned material is counted; freight, tax, tools and labor are separate.
Perception Desktop checks connect the recovered litter model to the read-only operator preview. Actual camera/Pi commissioning and useful field detection remain unverified; earlier benchmarks are separate evidence.
Simulation V1 simulation lab · Current CAD, recorded Newton runs, interactive MuJoCo physics and two mapped real sites. Dynamics and terrain remain uncalibrated; this does not qualify field operation or six-hour endurance. Assembly review.
Still to verify Delivered-part fit, wiring and stop behavior, loaded movement and jaw holding, bin/battery swaps, hot-weather operation and useful runtime.
Field pickups 0 no chassis on a route yet
§ 06 · What we're working on

What we're working on.

01

Build the first frame

The current CAD, workshop drawings and assembly sequence support an unpowered frame build. Delivered-part fitting and powered tests follow. Meet the current V1 →

02

Connect the model to measurements

The V1 simulation uses the current geometry and mapped sites. The next evidence is physical: traction, loaded stopping, jaw holding, temperature and useful runtime.

03

Grime Ward in the field

Web beta and internal TestFlight support discovery, private visits and shared contributions. Real-account sign-in, physical-device camera use and field usability remain part of testing.

§ 07 · Who

DregsBane Systems LLC is a Virginia company, formed April 2026, building infrastructure against physical neglect: CrustBot, a remotely operated vehicle being prepared for assembly, and Grime Ward, a place journal and cleanup companion in beta.

It is deliberately small — everything on this site was designed, built, benchmarked, and deployed in-house. The build log is the honest record of who we are: what shipped, what didn't, and what the numbers actually say.

Contact: hello@dregsbane.com